Quadruped Robot & Locomotion Sim
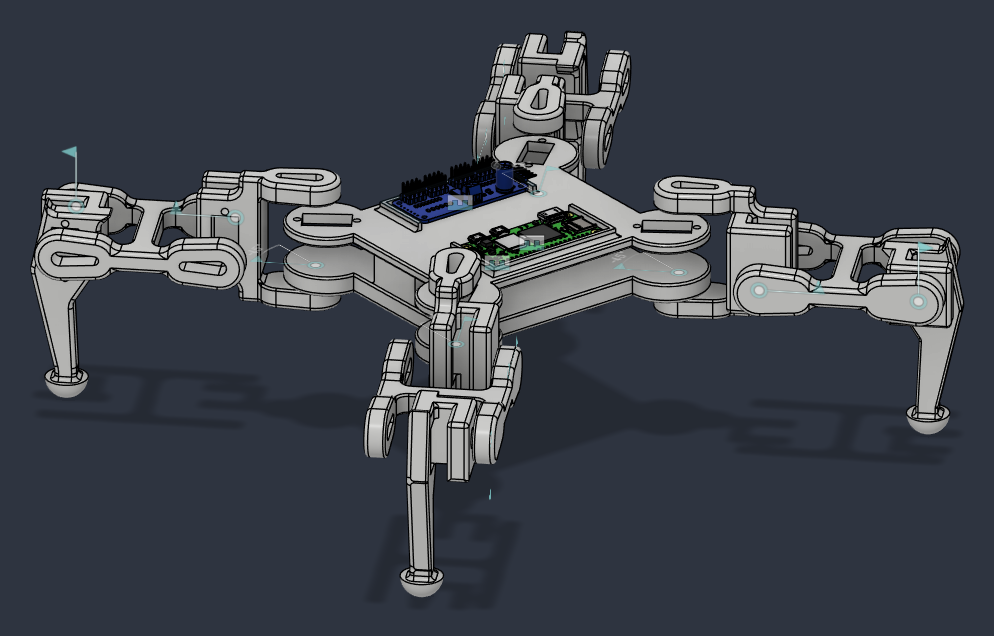
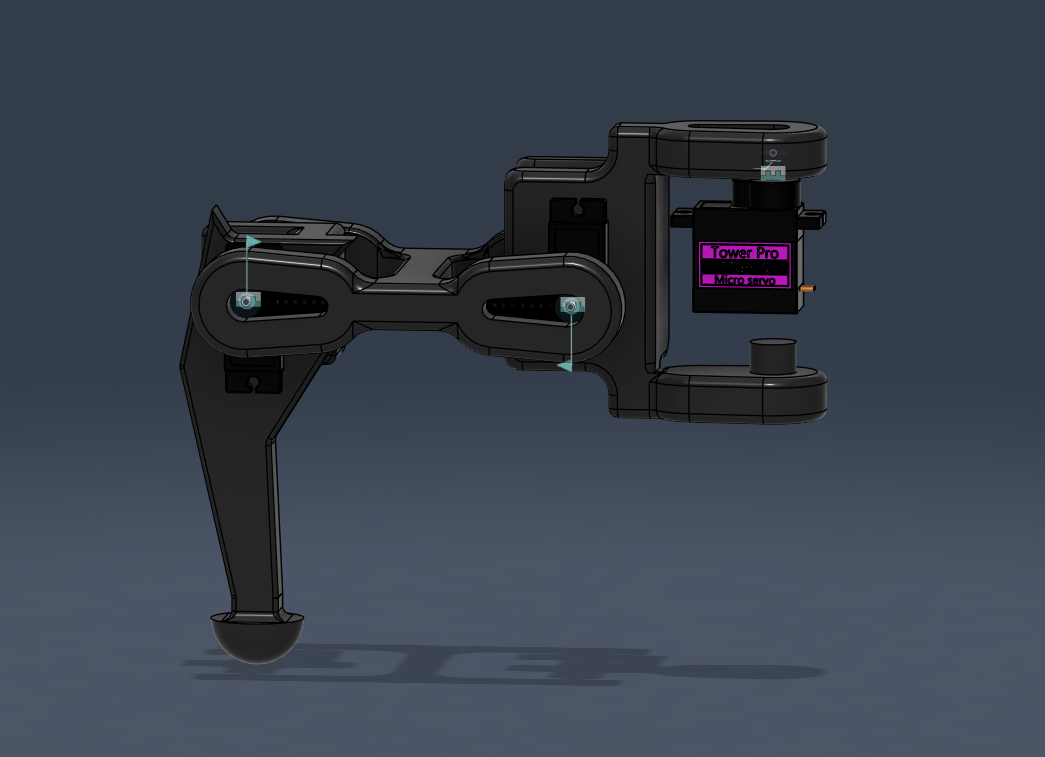
12-servo, 3D-printable quadruped designed in Fusion 360, exported to URDF and simulated in MuJoCo. A trot gait controller makes it stand, walk and turn on the spot, and drives the real servos through a PCA9685 board. Works flawlessly in simulation, where gravity is a tidy constant and friction never betrays you.