Type a command, or pick one from the bar below. Try .
I build robots, design mechanical parts, and work on nuclear tooling, ranked in ascending order of paperwork.
B.Eng. Mechatronics Engineering Co-op (Level III), McMaster University
Available for a Spring 2027 co-op.
Featured:
Quadruped robotWishbone suspension (concept)WheelSafe, top 3 of 200+
More:
Projects
Quadruped Robot & Locomotion Sim
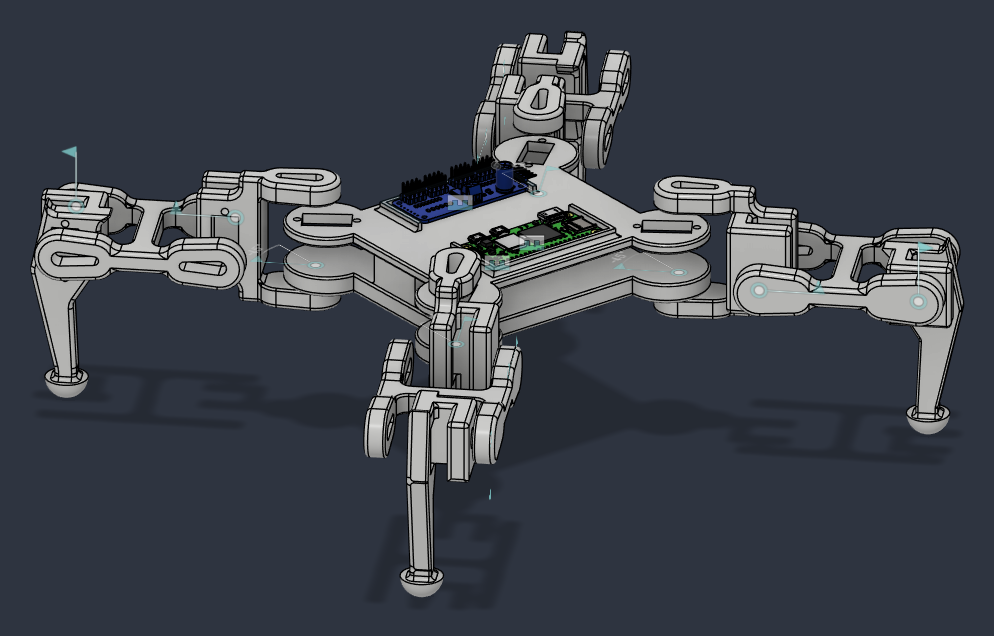
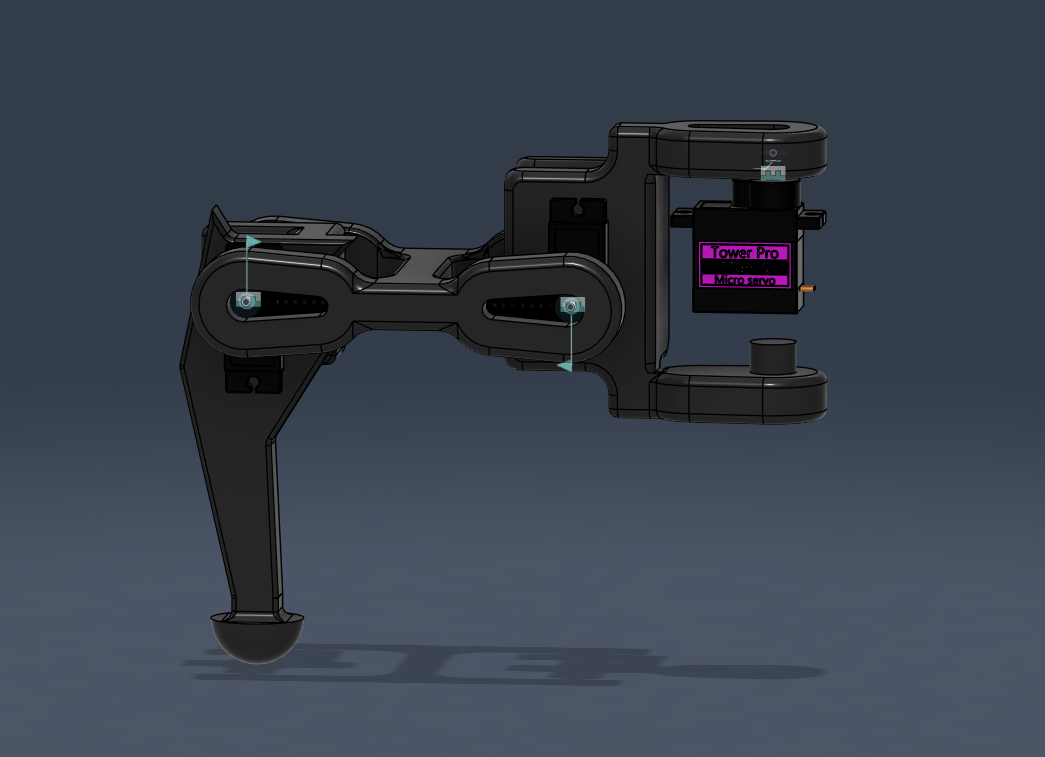
A 12-servo, 3D-printable quadruped designed in Fusion 360, exported to URDF and simulated in MuJoCo. A trot gait controller makes it stand, walk and turn in place, and drives the real servos through a PCA9685 board on a Raspberry Pi. It walks perfectly in simulation, where friction always behaves.
Proof-of-concept double wishbone geometry in SolidWorks for McMaster Chem-E-Car's 2026–2027 season. Nothing is built yet: the point was to work out the kinematics and see how the linkage could control dynamic camber to keep a 500 mL sloshing payload stable over a 33 m run. More suspension than a straight line strictly needs, but the camber curves are worth it.
SolidWorks, kinematics, vehicle dynamics
WheelSafe Storage
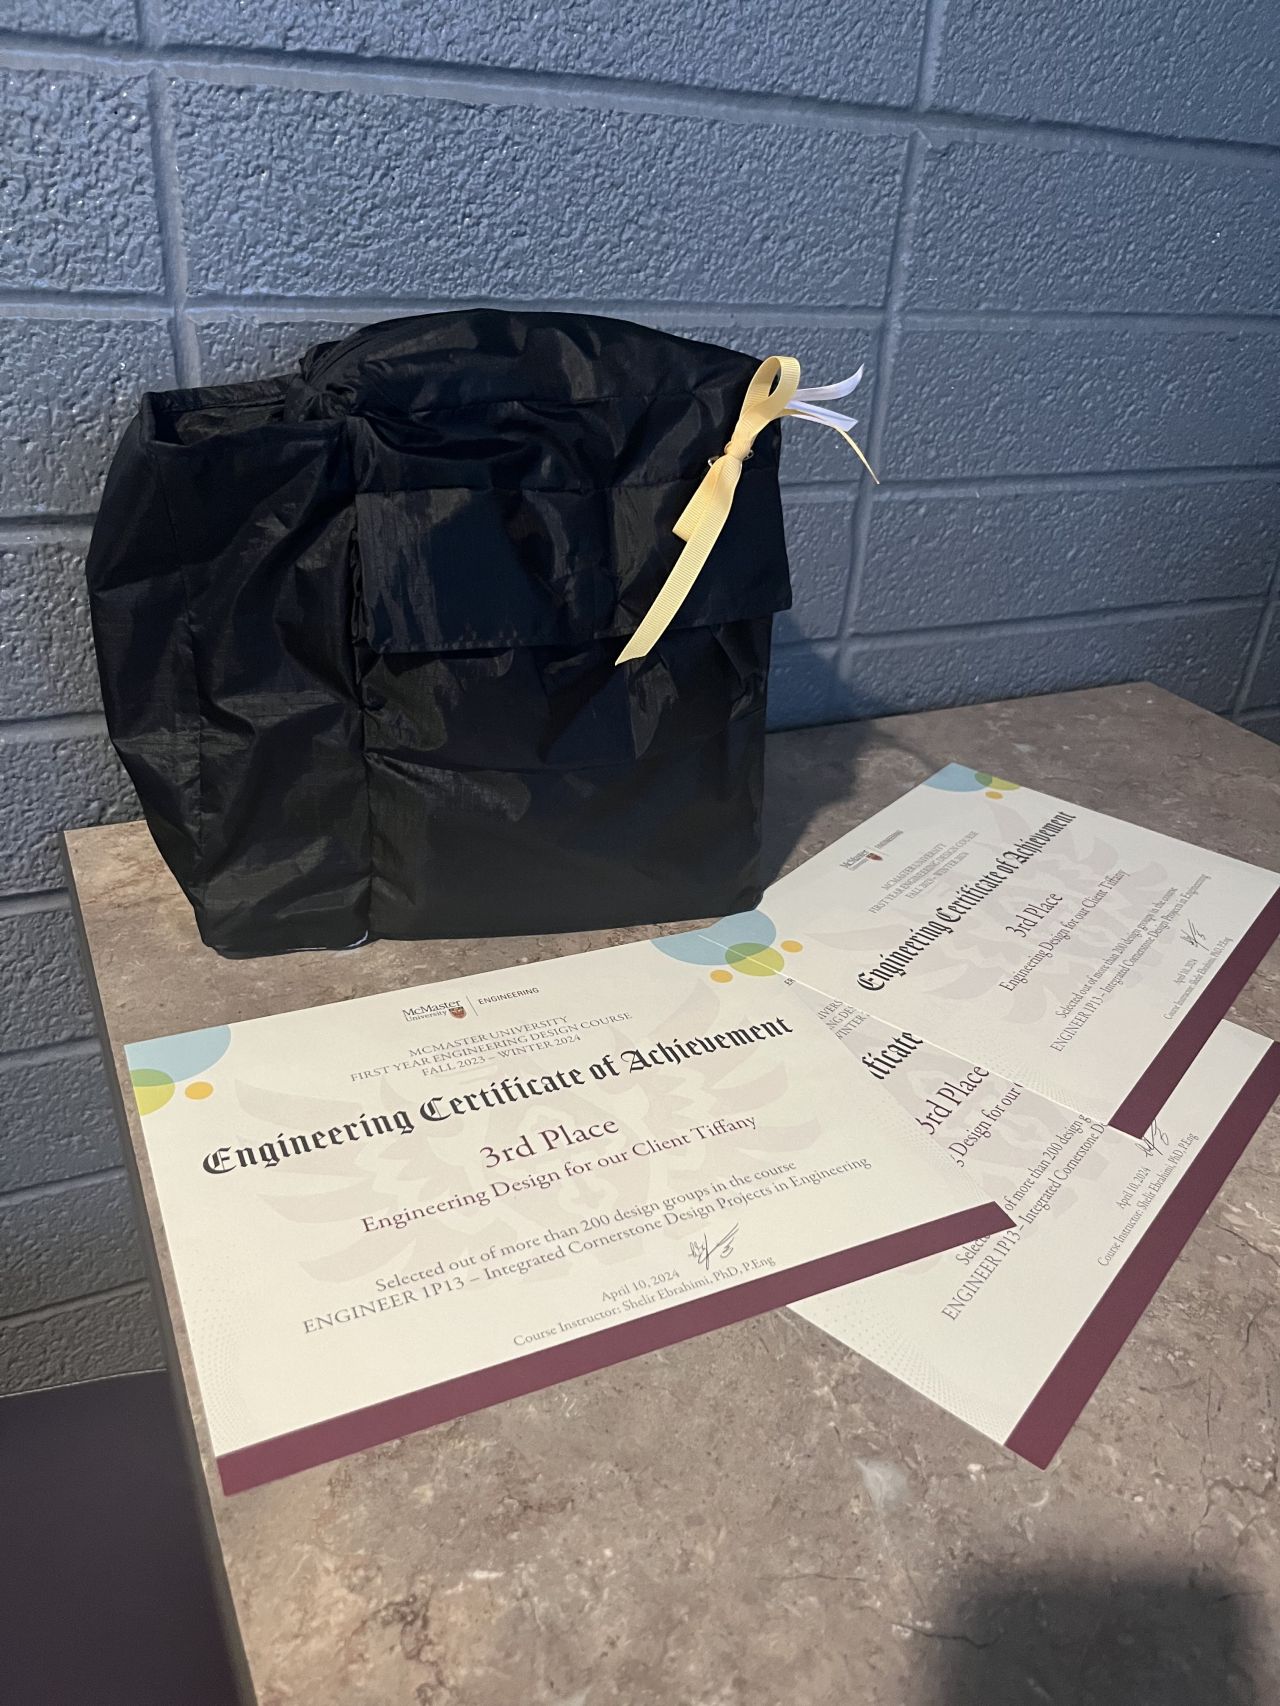
An ergonomic, weatherproof wheelchair storage module designed for a client with spina bifida. The 0.4 kg carbon-fiber-reinforced structure reached a 3.25:1 load-to-weight ratio. Placed top 3 of 200+ teams at the McMaster Design Showcase.
Built in 12 hours, about as long as SolidWorks takes to open. A real-time OpenCV hand-tracking pipeline streams coordinate deltas over UDP to an ESP32, which turns them into smooth stepper motor pulses.
OpenCV, ESP32, C++, UDP
Globe Ghost — iOS GPS Simulator
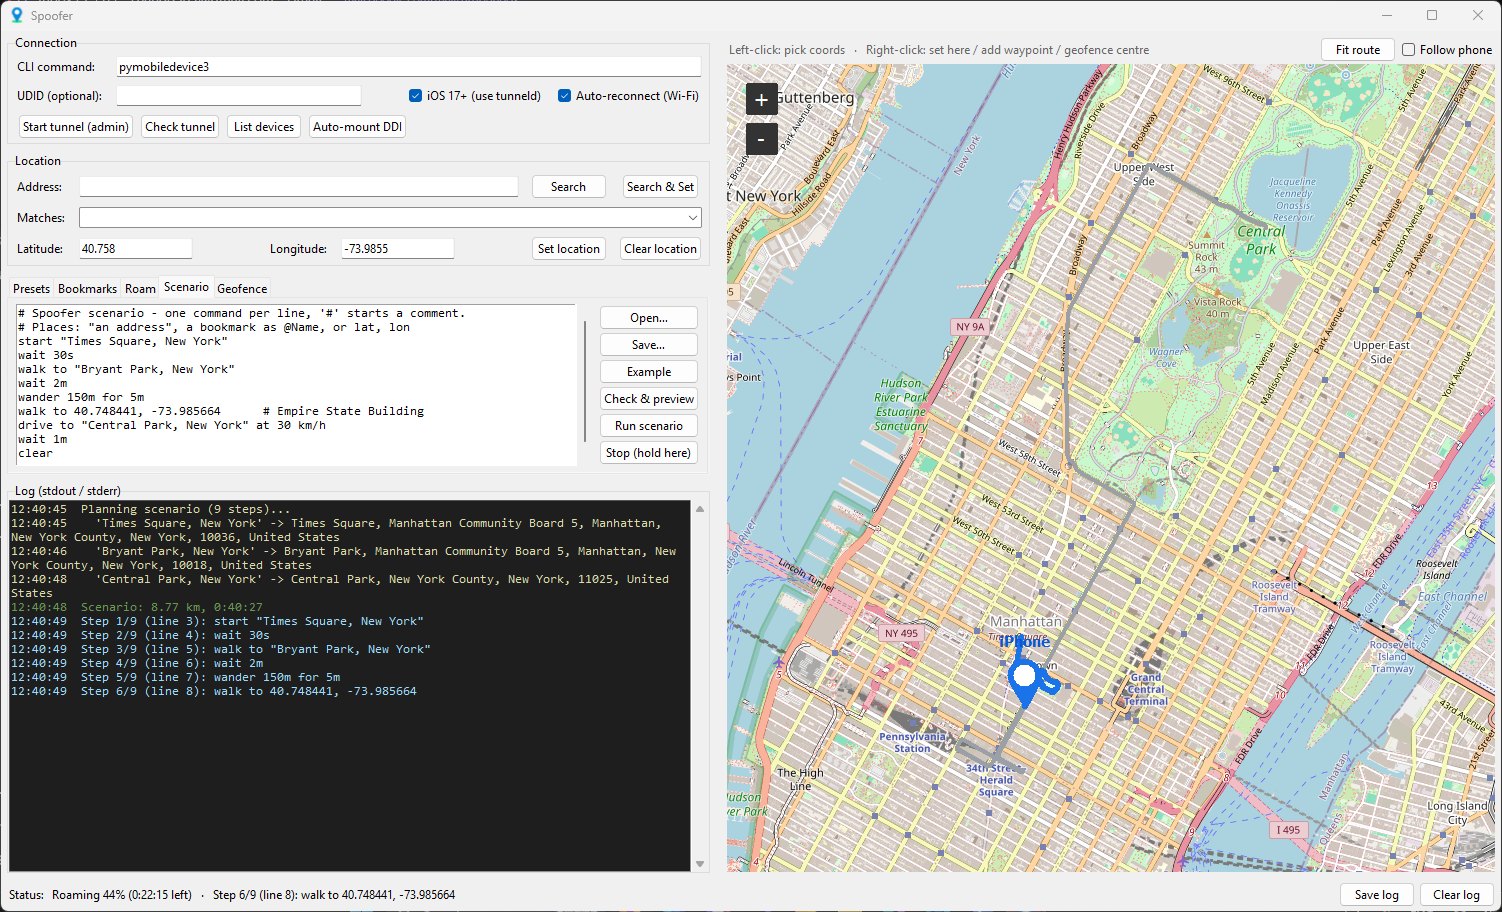
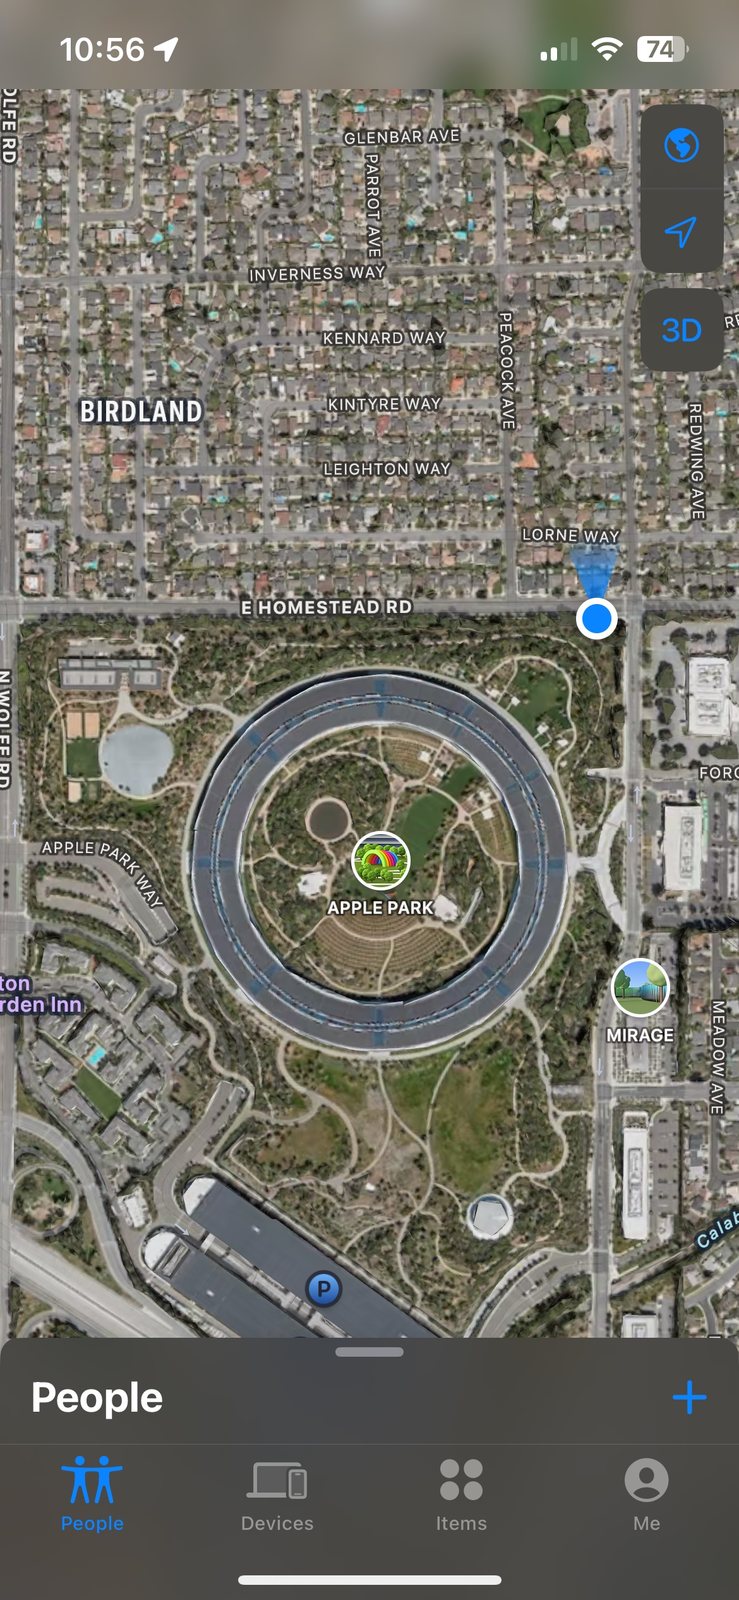
Sets an iPhone's actual GPS location, not just its IP address like a VPN does, for testing location-aware apps. Includes a live map, scripted routes and a geofence tester. Find My now thinks I've been to California.
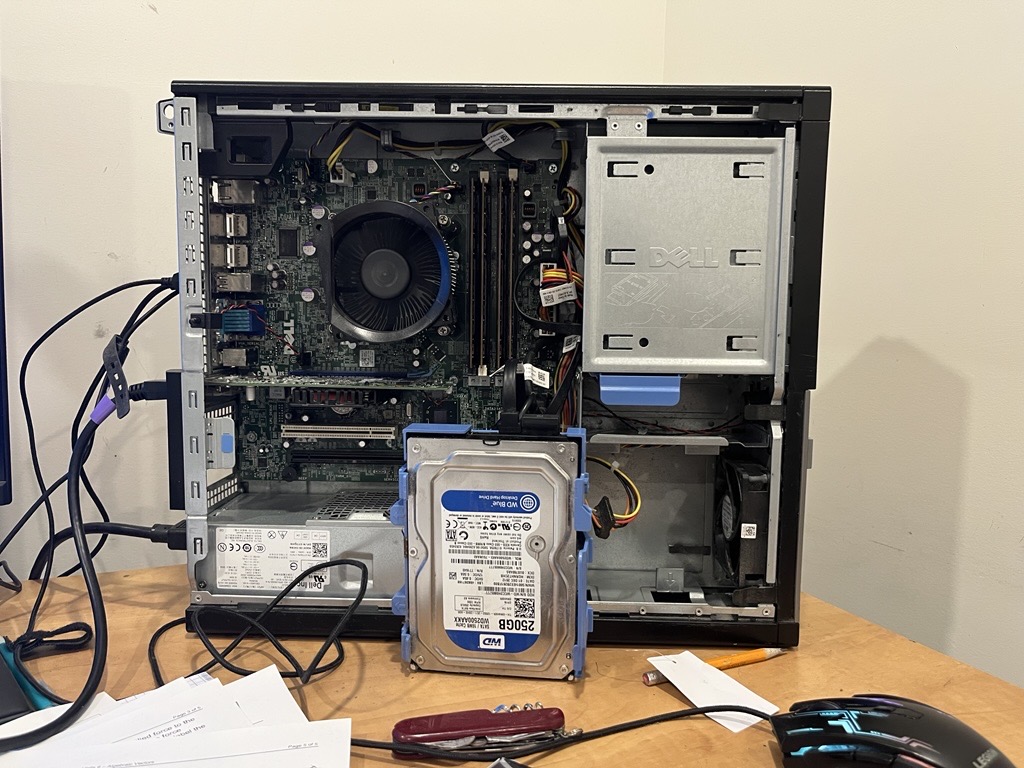
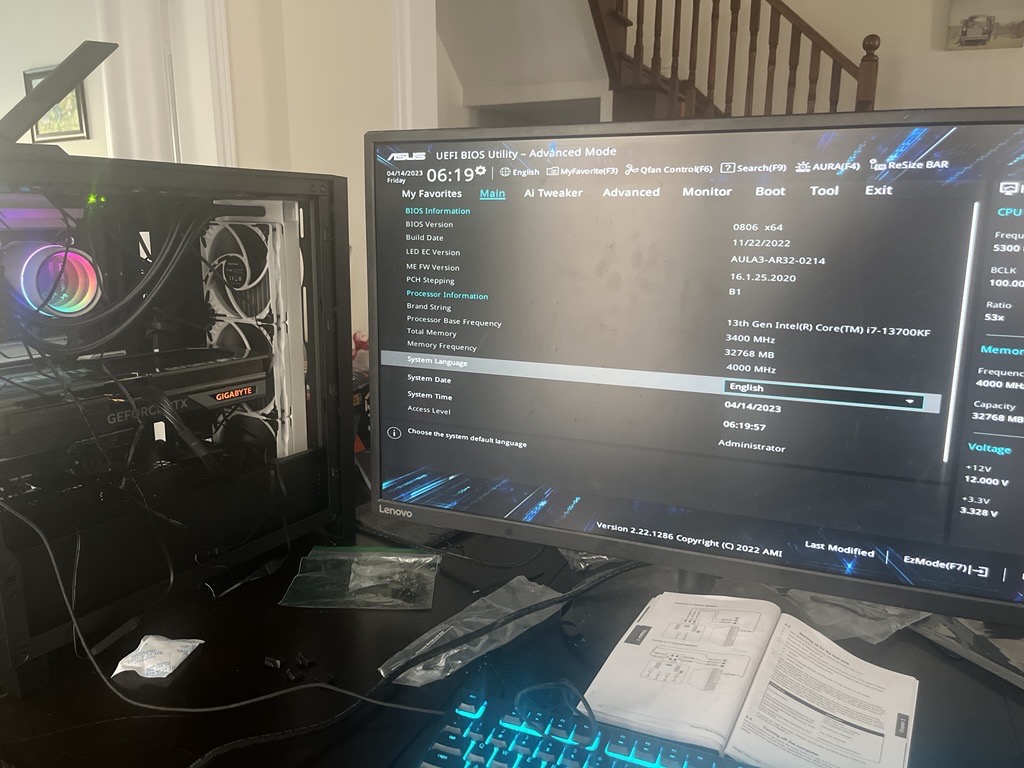
Chem-E-Car transmissionQuadruped assemblyLeg linkageHV discharge testAccidental RF antennaGlobe Ghost field testRebuilt Dell serverNew build, first boot
Experience
Jan 2026 – present
Nuclear Engineering Intern, Eclipse Automation
Tooling design and verification for CANDU sites, including Pickering and international stations. Performed ASD calculations and weldment FEA, wrote FMEAs, and tested CSA N299.2-rated tooling. Nuclear turns out to be roughly 10% tooling, 90% paperwork.
Designing custom wheel assemblies and suspension geometry for the 2026–2027 car, to keep 500 mL of water from sloshing over a 33 m run. Overkill, but the geometry checks out.
2024
Top 3 Finalist, ENGINEER 1P13 Showcase, McMaster University
Placed top 3 of 200+ teams with a carbon-fiber wheelchair storage unit, presented to a panel of P.Eng judges, and survived the questions.
2023 – present
B.Eng., Mechatronics Engineering Co-op (Level III), McMaster University
Statics, dynamics, embedded systems, circuit theory, and math that feels made up until co-op needs it.
Skills
Hardware
STM32, ESP32, Raspberry Pi, PCA9685 / motor drivers, NI Multisim, soldering, 3D printing
One page; every bullet had to earn its spot. Covers nuclear tooling at Eclipse Automation, wheel and suspension design for Chem-E-Car, and legged-robot and computer vision projects.